The world of rovers · 118–119
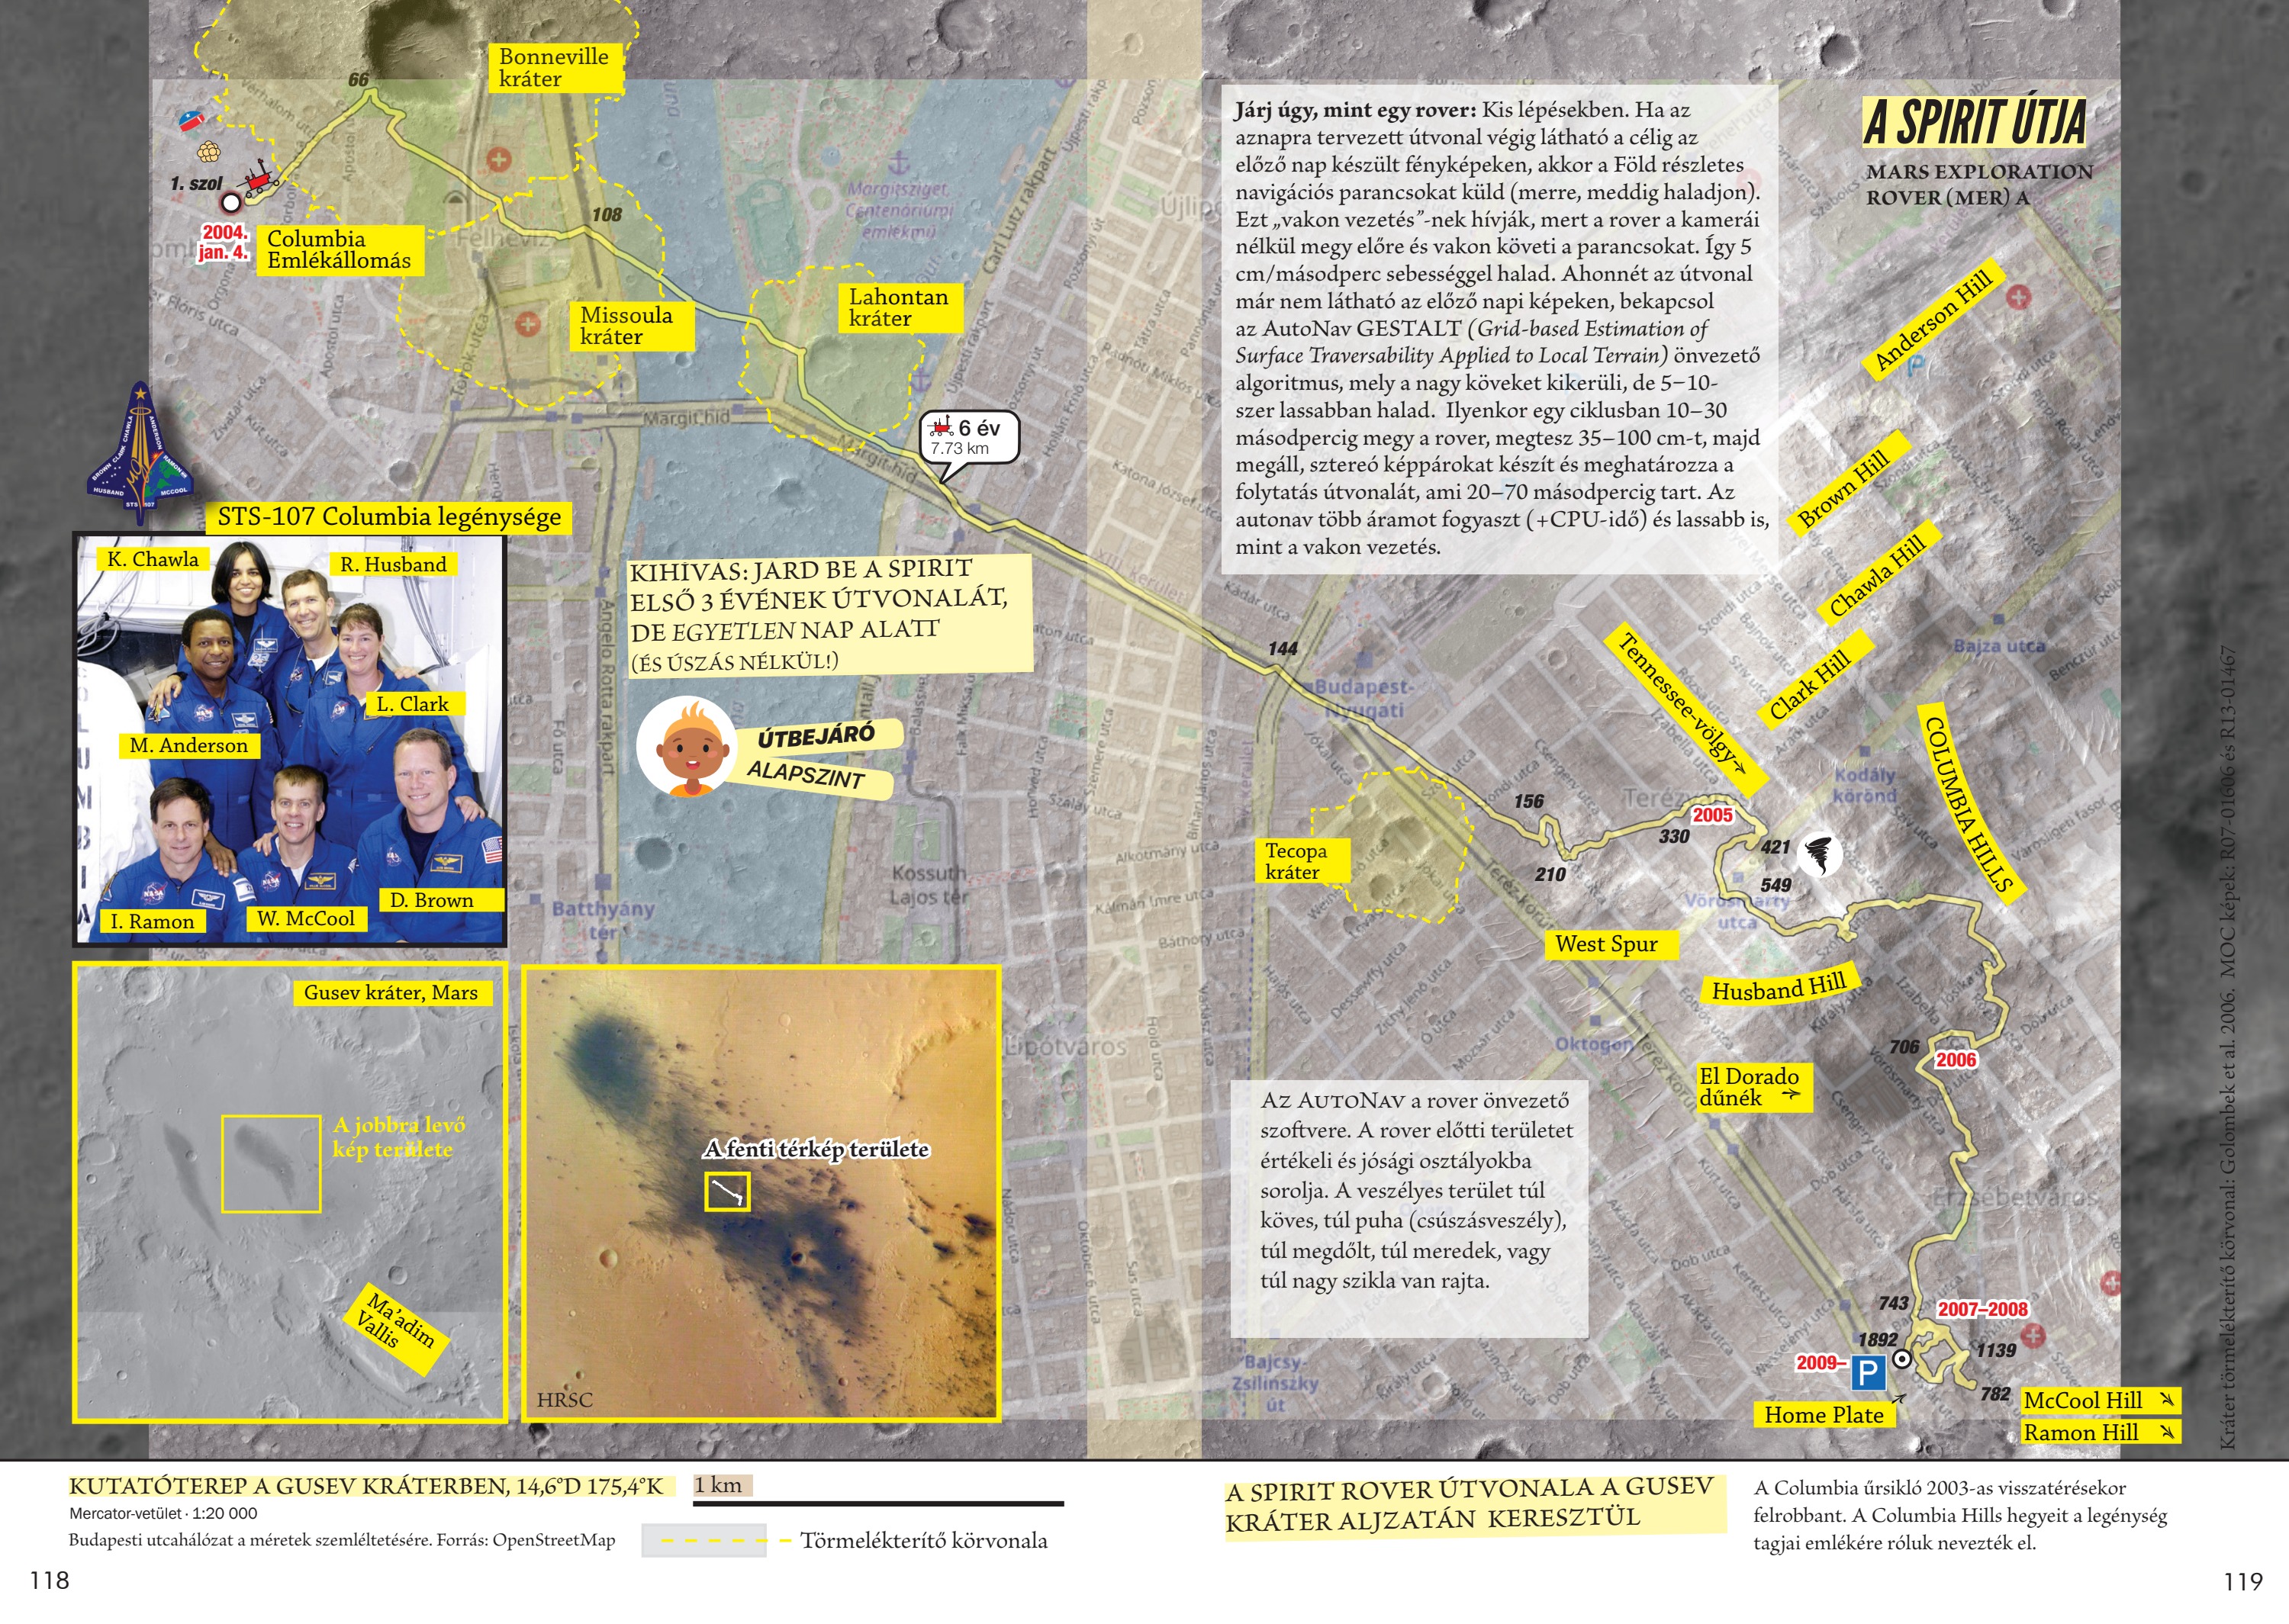
The route of the Spirit rover
Zoom with the mouse wheel inside the image or use the buttons. Drag the enlarged image with the hand cursor; swipe to move on a touchscreen.
Walk like a rover: in small steps. If the day’s planned route is visible all the way to its destination in the previous day’s pictures, Earth sends detailed commands specifying direction and distance. This is called blind driving: the rover proceeds without using its cameras, following the commands at 5 cm per second. Beyond the visible route, the AutoNav GESTALT algorithm takes over, avoiding large rocks but moving five to ten times more slowly. In each cycle, the rover moves for 10–30 seconds, covers 35–100 cm, stops, takes stereo pictures and spends 20–70 seconds choosing the next segment. AutoNav consumes more power and processor time and is slower than blind driving.